Shintaro Inoue
  • Projects
  • Robots
  • Videos
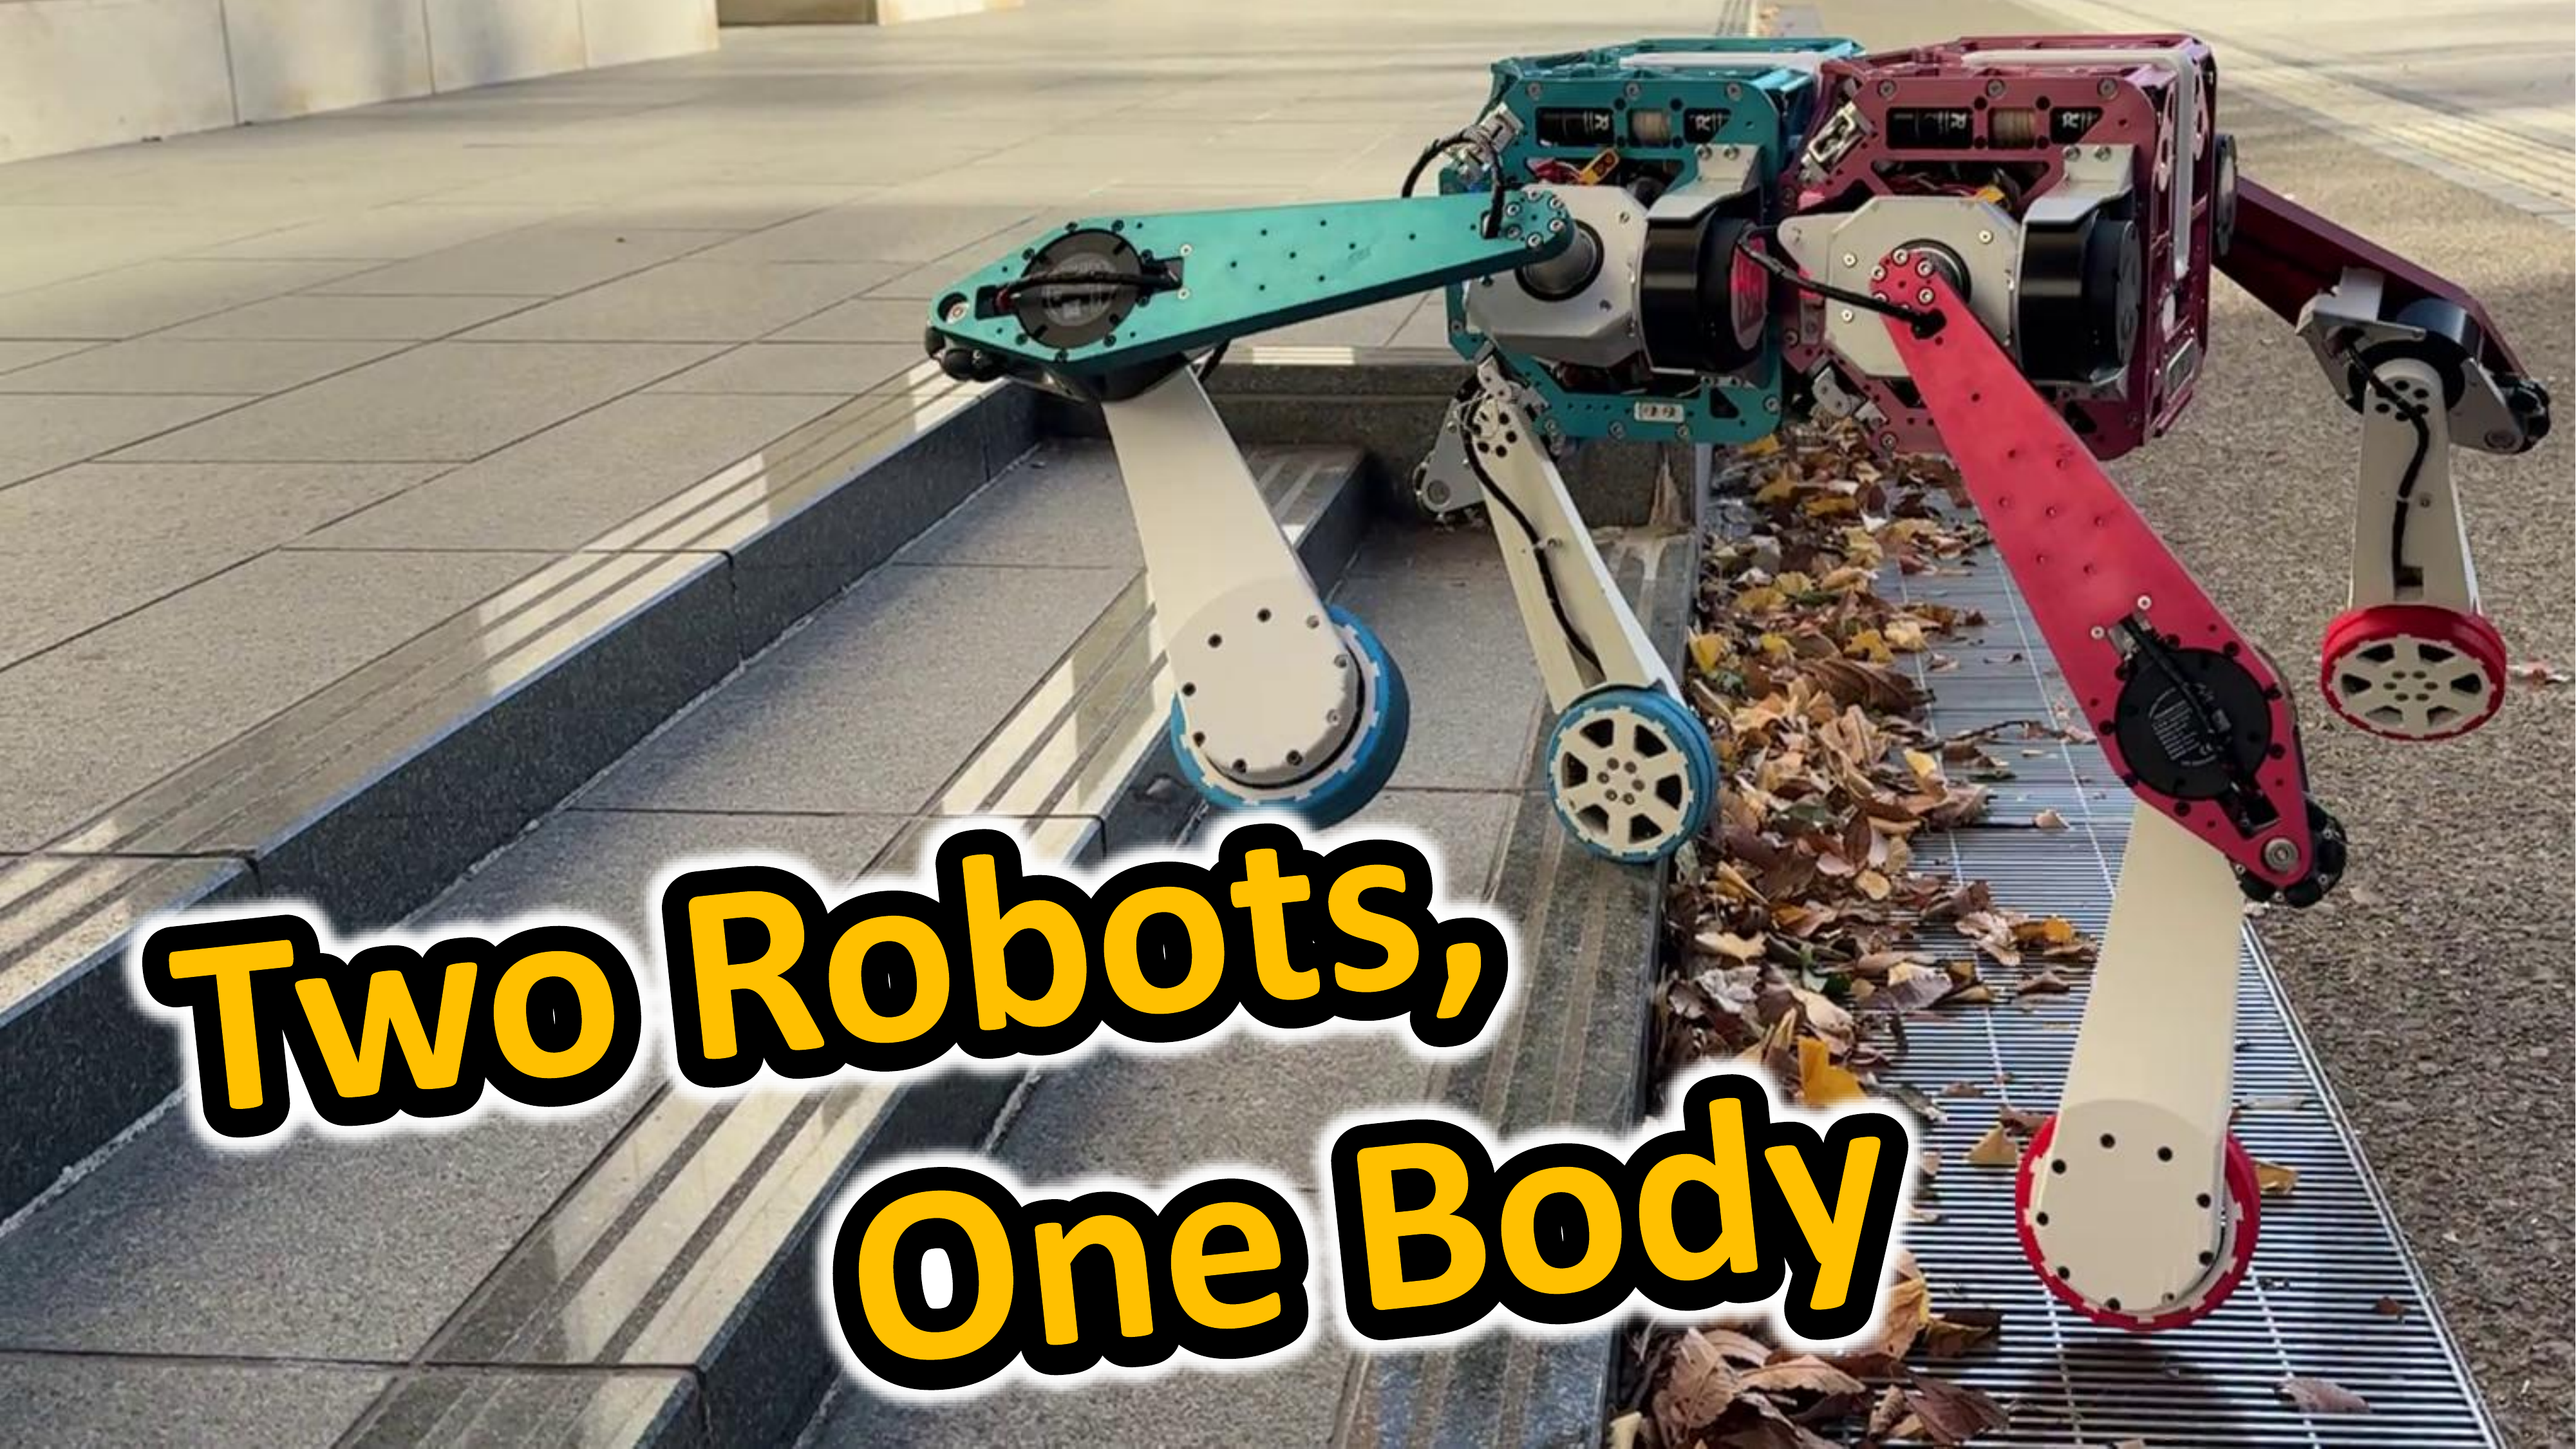
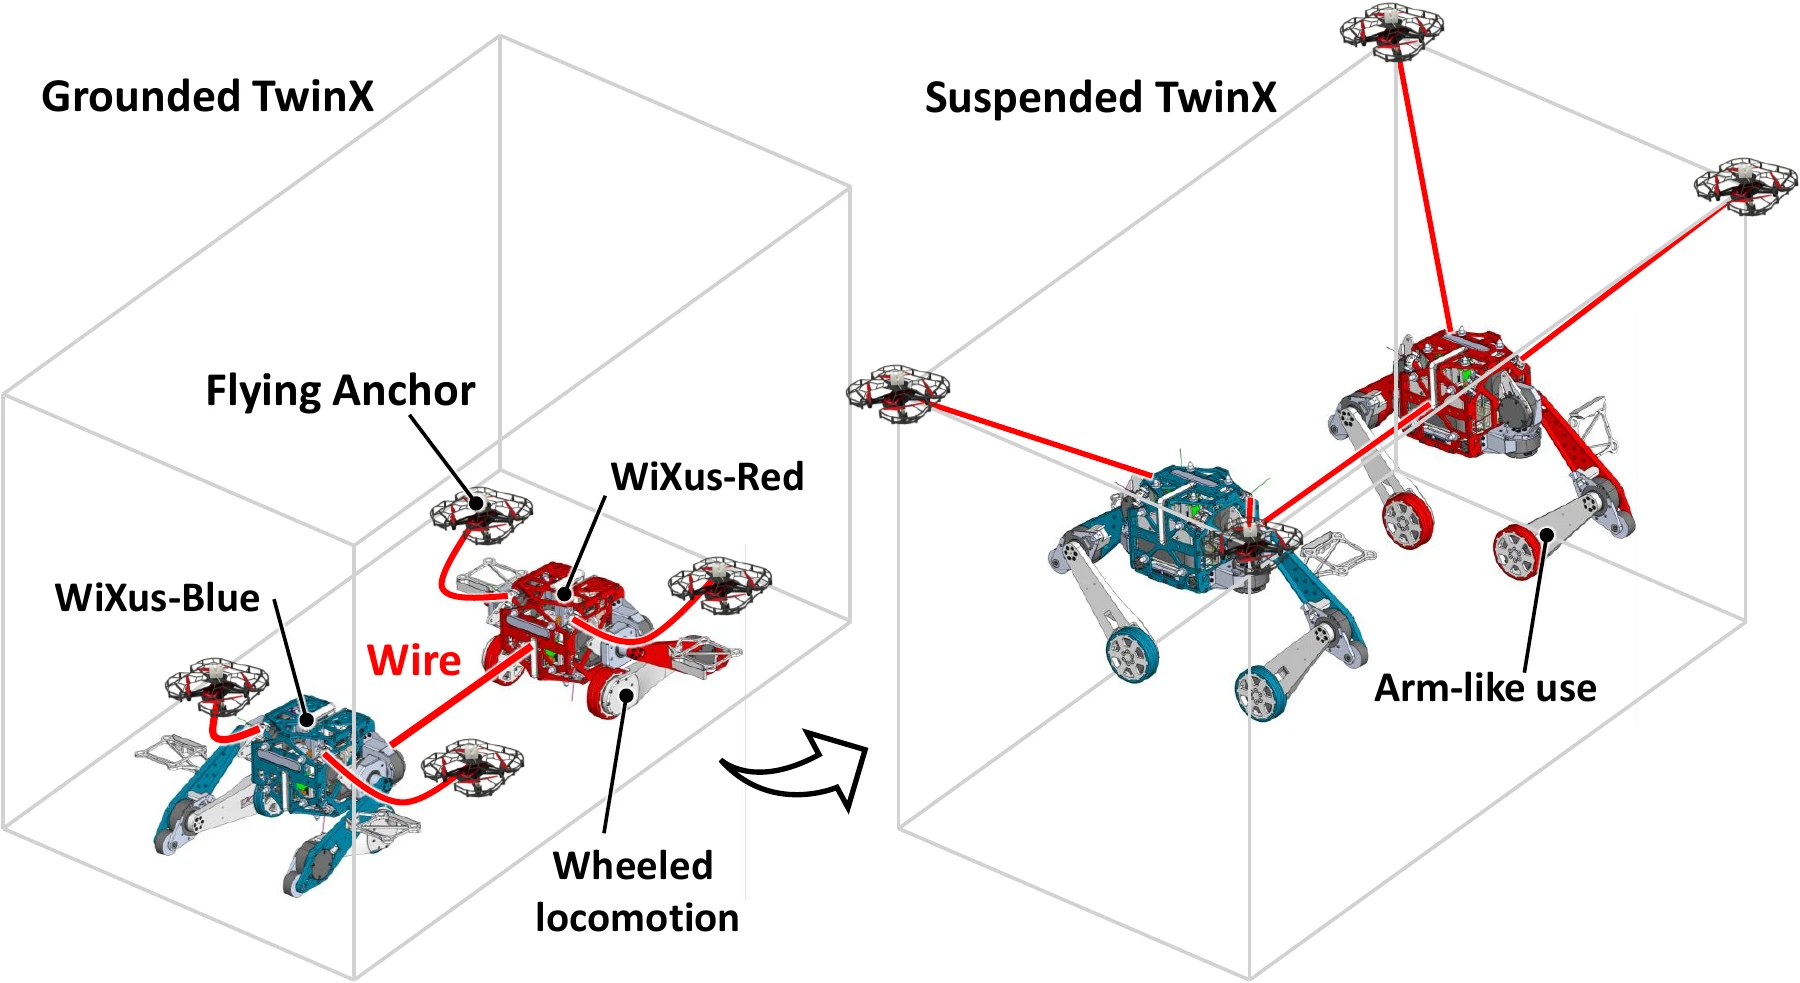
Inter-Body Wire for Reconfigurable Robots: Bridging Integrated Morphological Reconfiguration and Distributed Wire-Mediated Cooperation

S. Inoue, K. Kawaharazuka, K. Yoneda, S. Yuzaki, T. Suzuki, K. Okada
Advanced Intelligent Systems (AISY), 2026

Extending Wire-Driven Parallel Robots to Multi-Floating-Link Systems With an Inter-Body Wire

S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Yoneda, K. Okada
IEEE Robotics and Automation Letters (RAL), vol. 11, no. 10, pp. 11314-11321, Oct. 2026

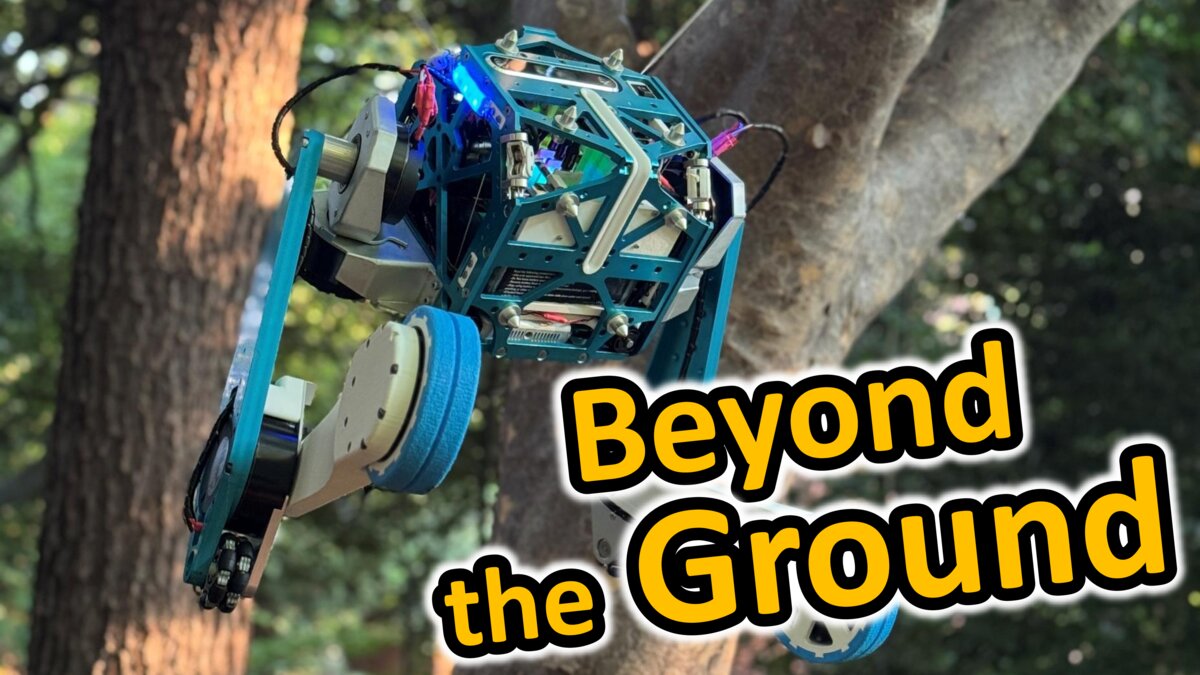
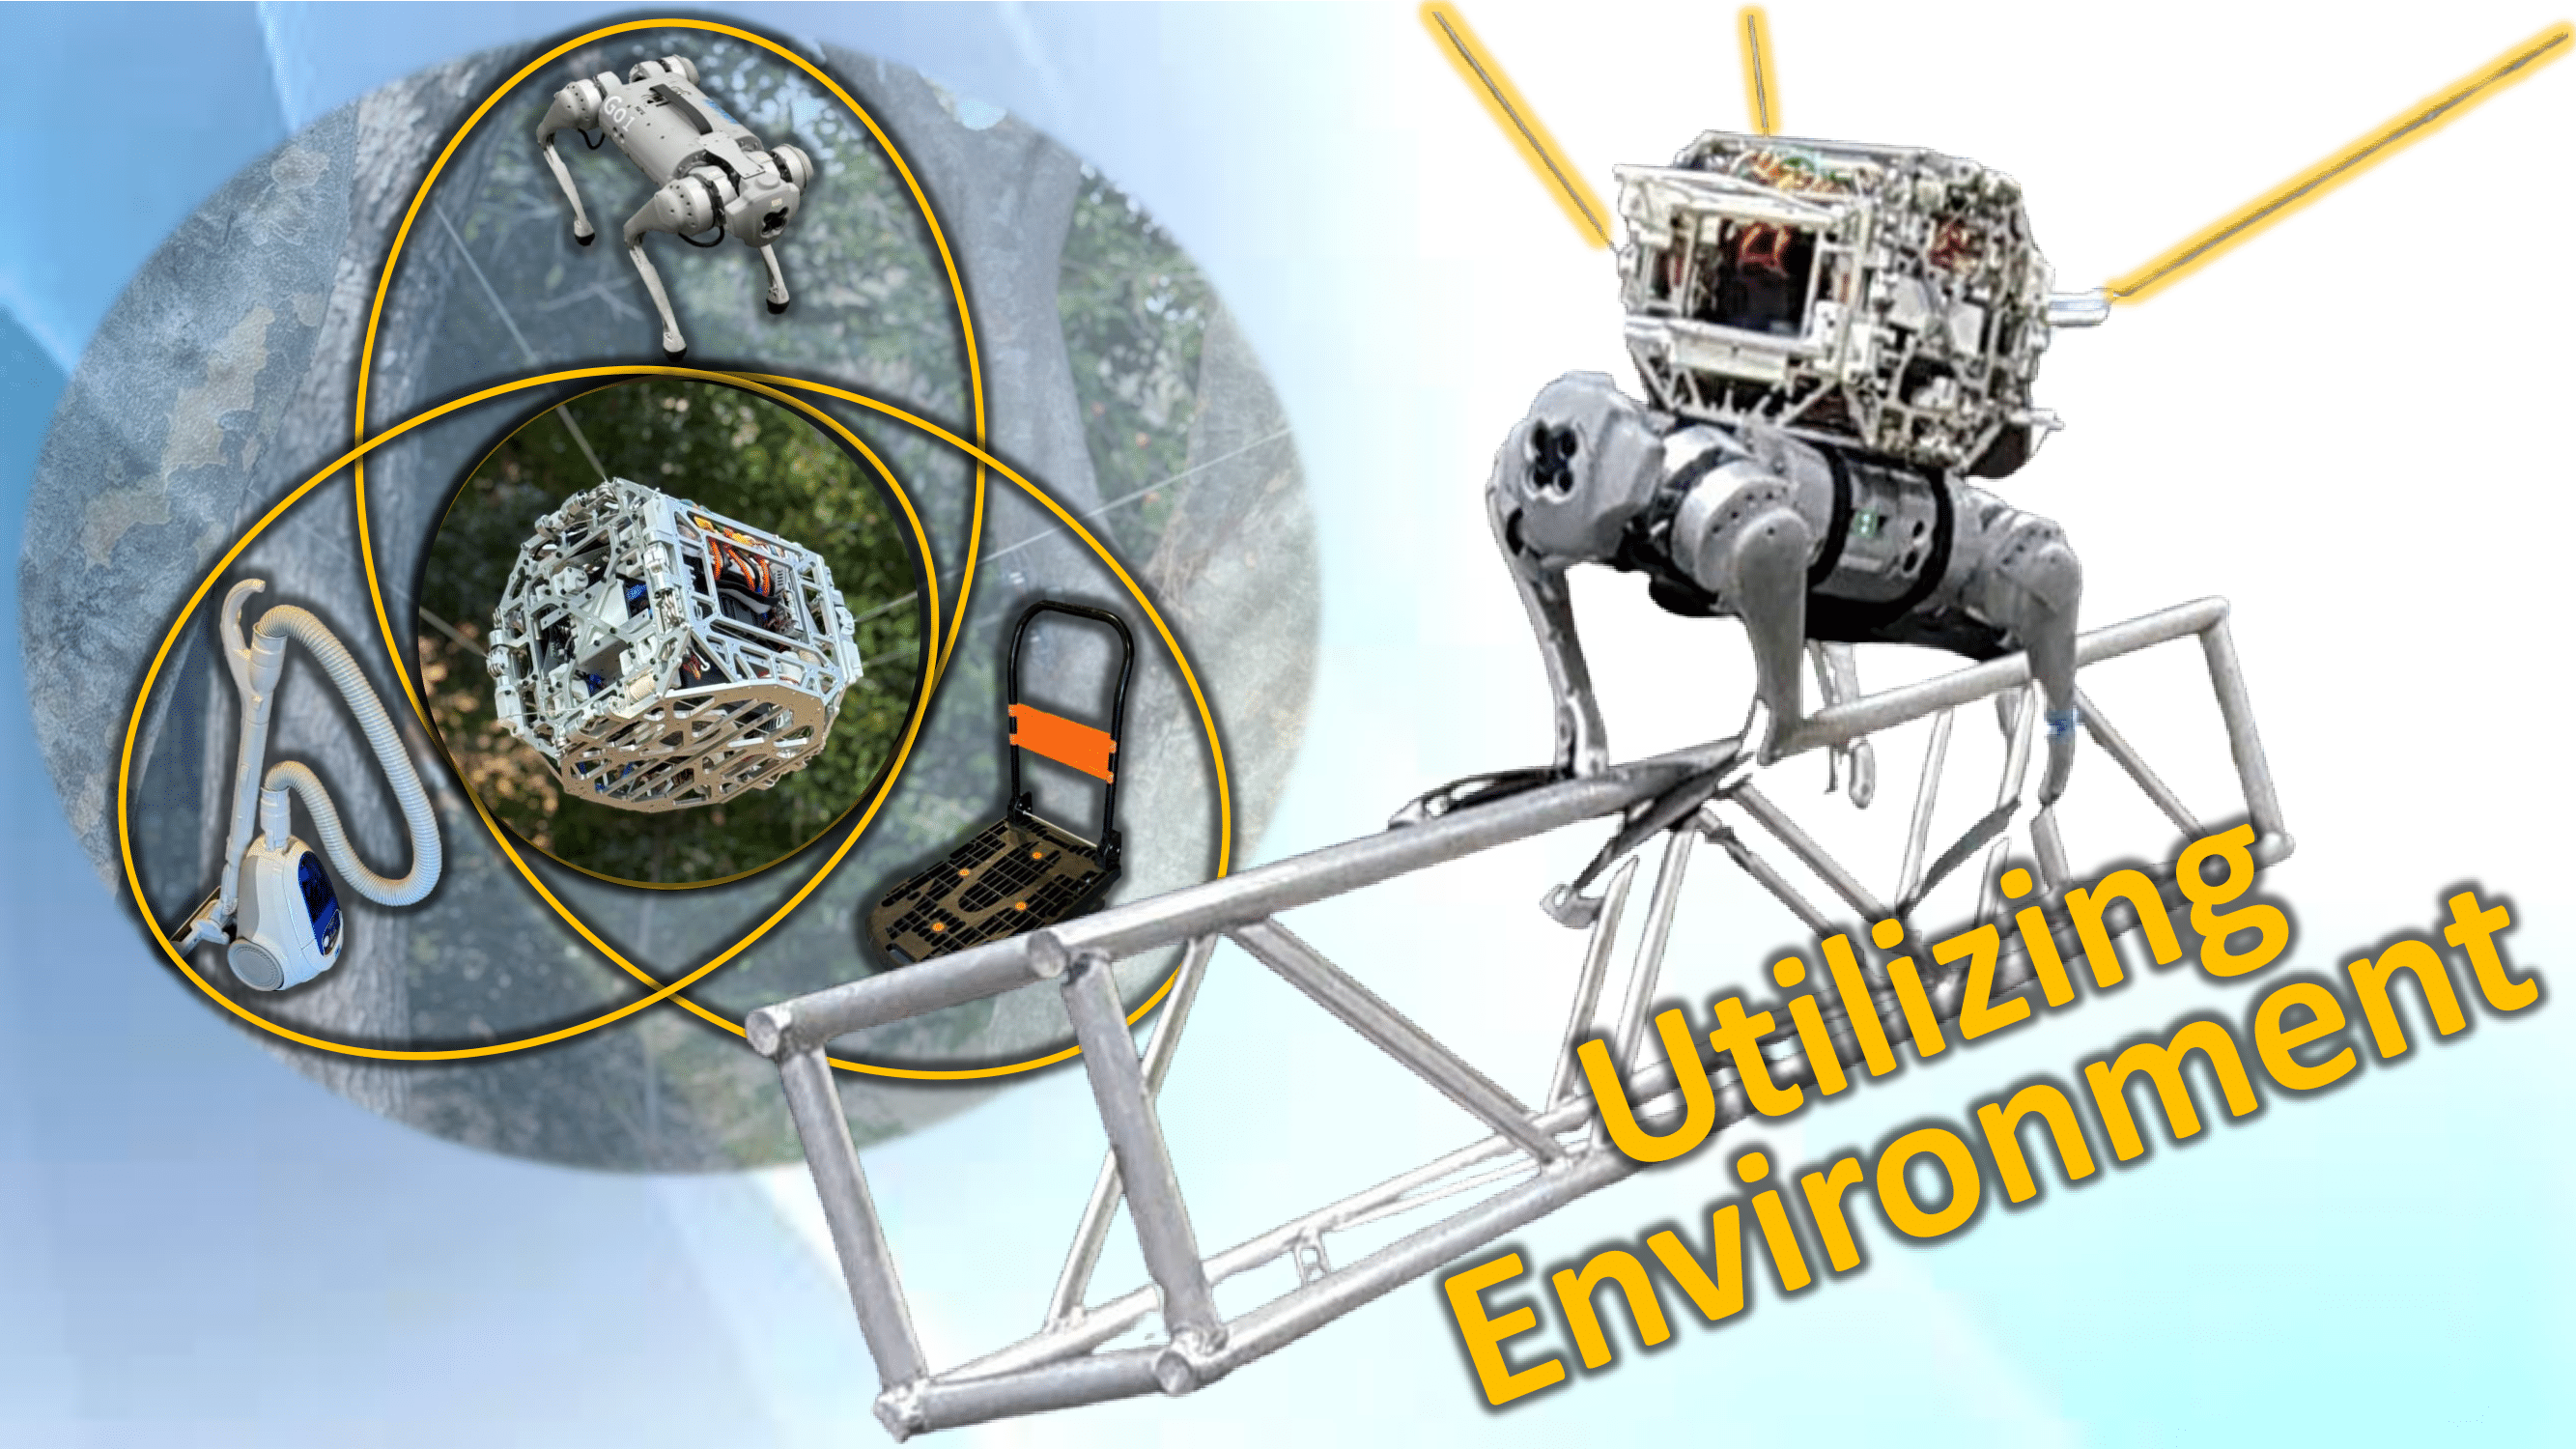
WiXus: A Wheeled-Legged Robot with Wire-Driven Environmental Utilizing to Integrate Mobility and Manipulation

S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Okada
Proceedings of the 2026 IEEE International Conference on Robotics and Automation (ICRA2026)

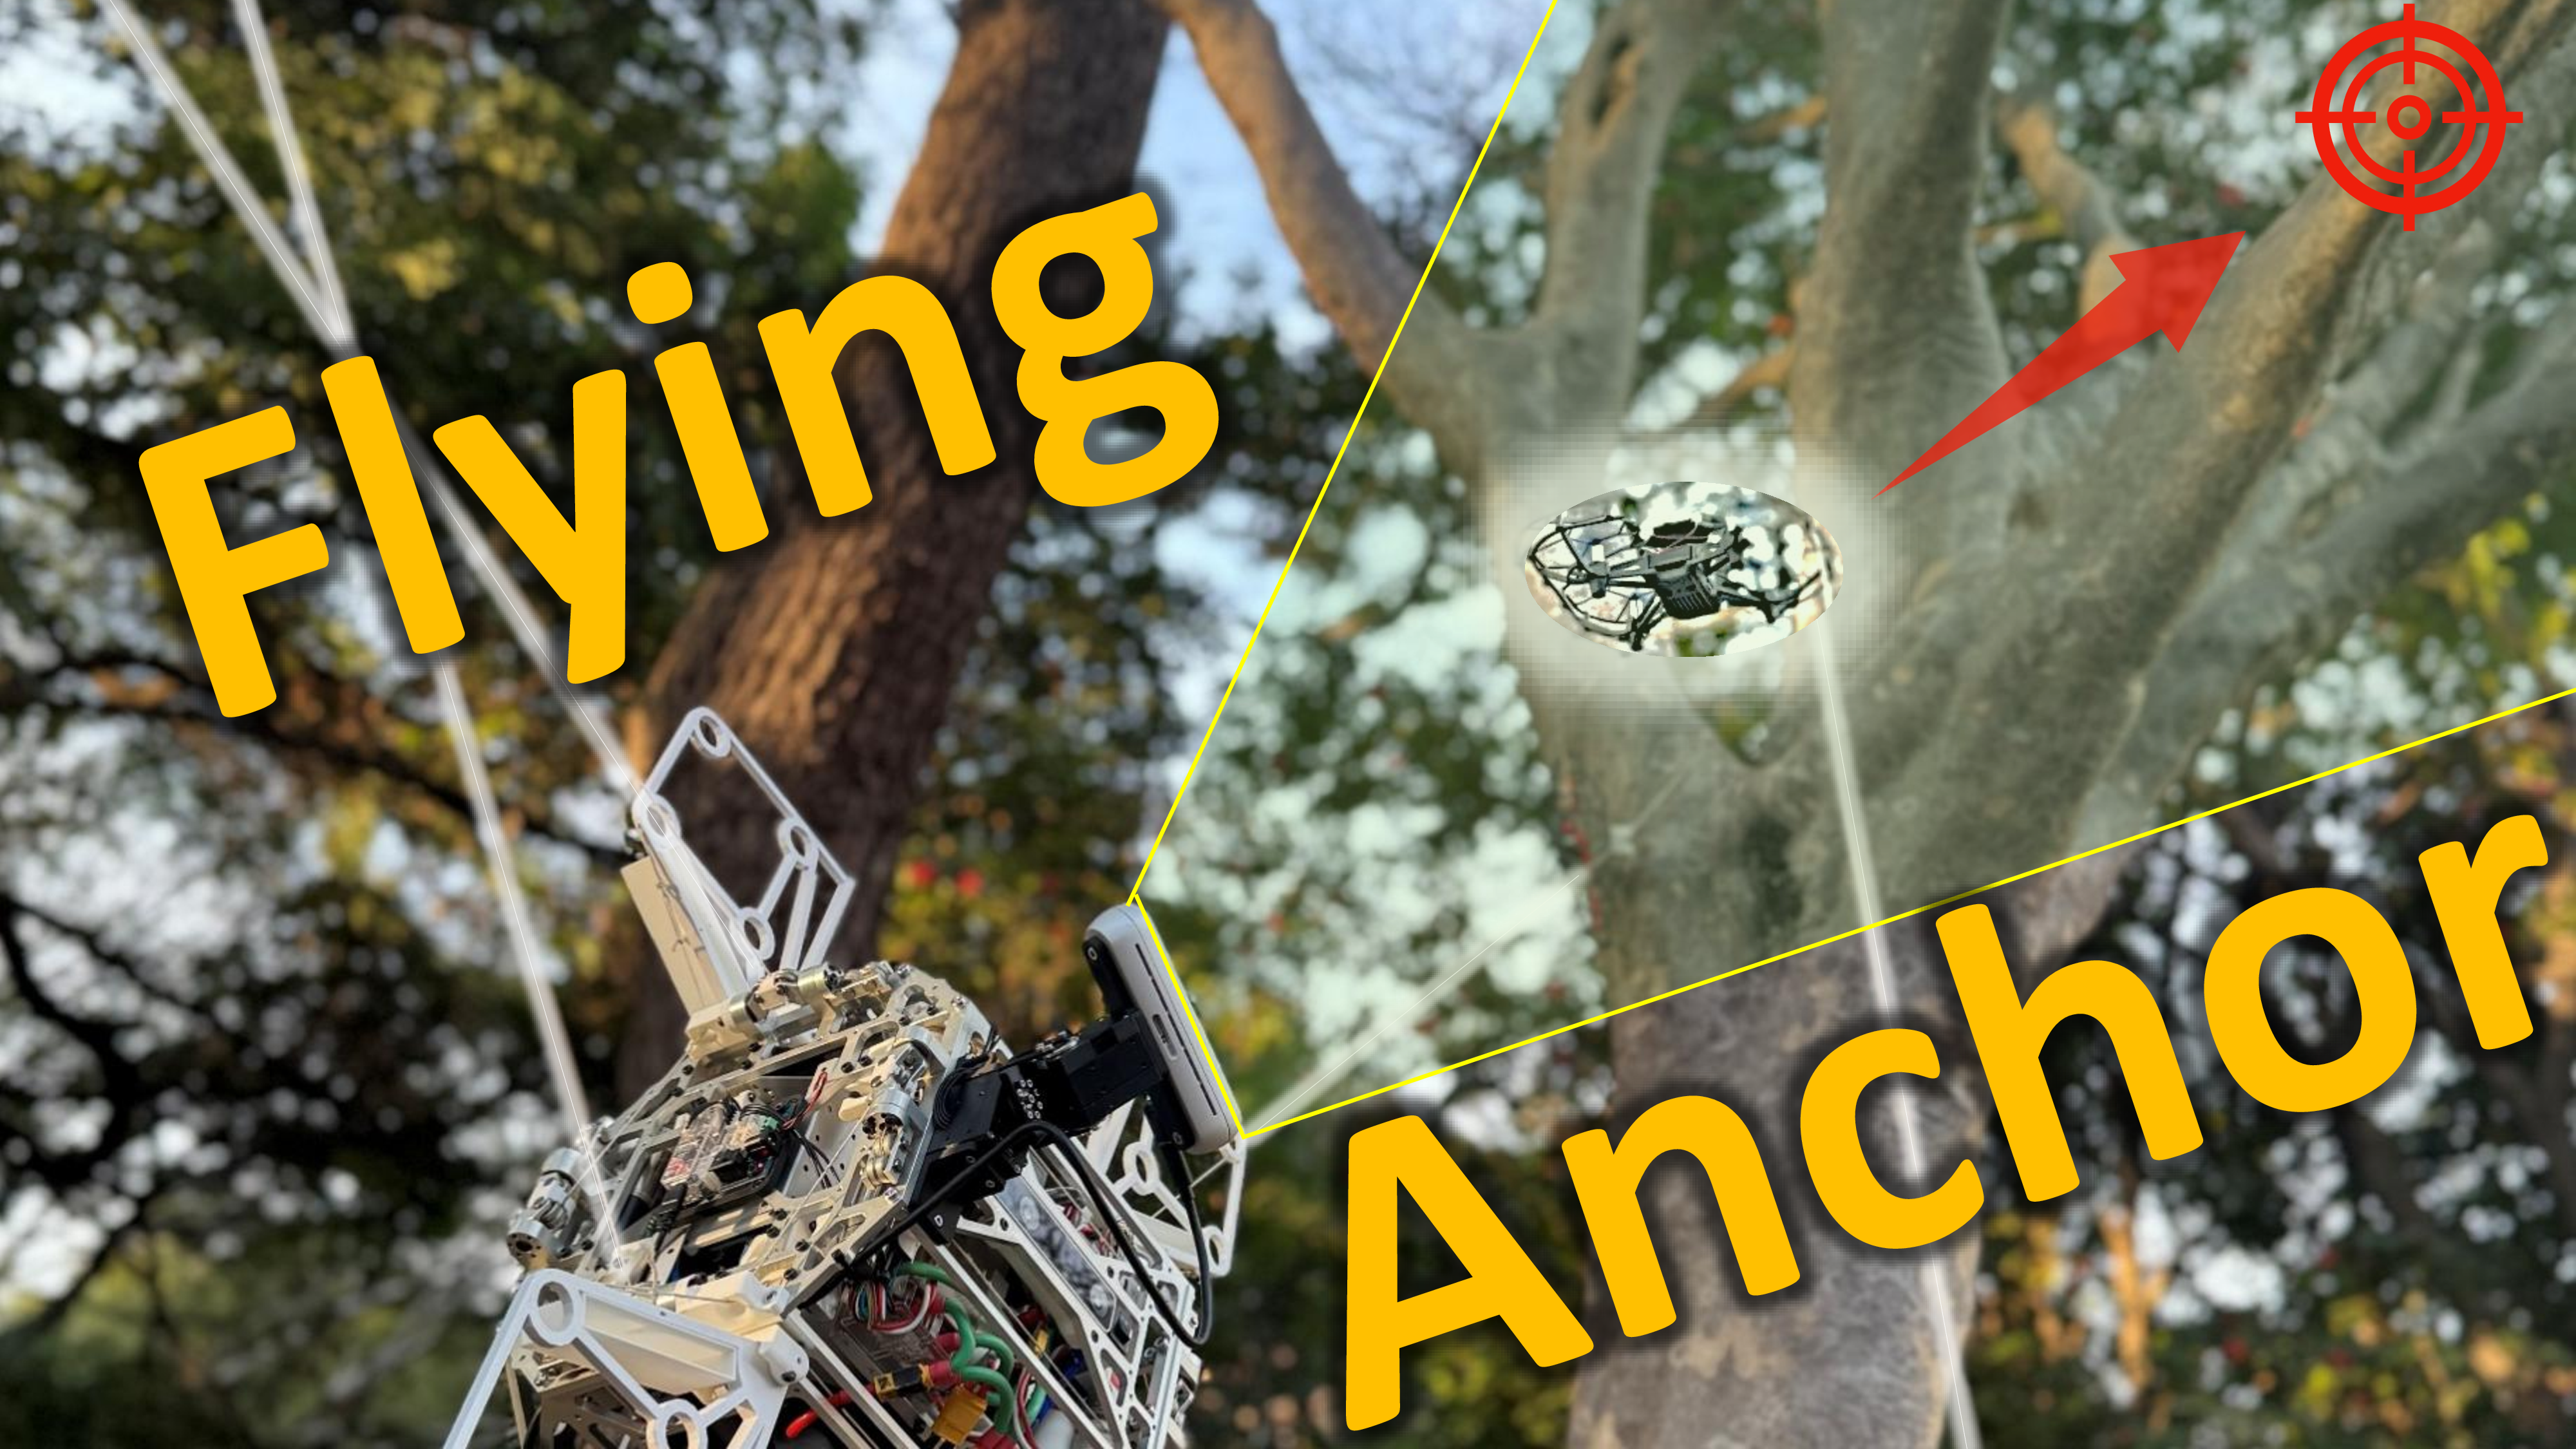
An RGB-D Camera-Based Multi-Small Flying Anchors Control for Wire-Driven Robots Connecting to the Environment

S. Inoue, K. Kawaharazuka, K. Yoneda, S. Yuzaki, Y. Sahara, T. Suzuki, K. Okada
Proceedings of the 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2025)

Overcoming Physical Limitations Utilizing the Surrounding Environment with a Wire-Driven Multipurpose Robot

S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Okada, M. Inaba
Advanced Robotics Research (ADRR)

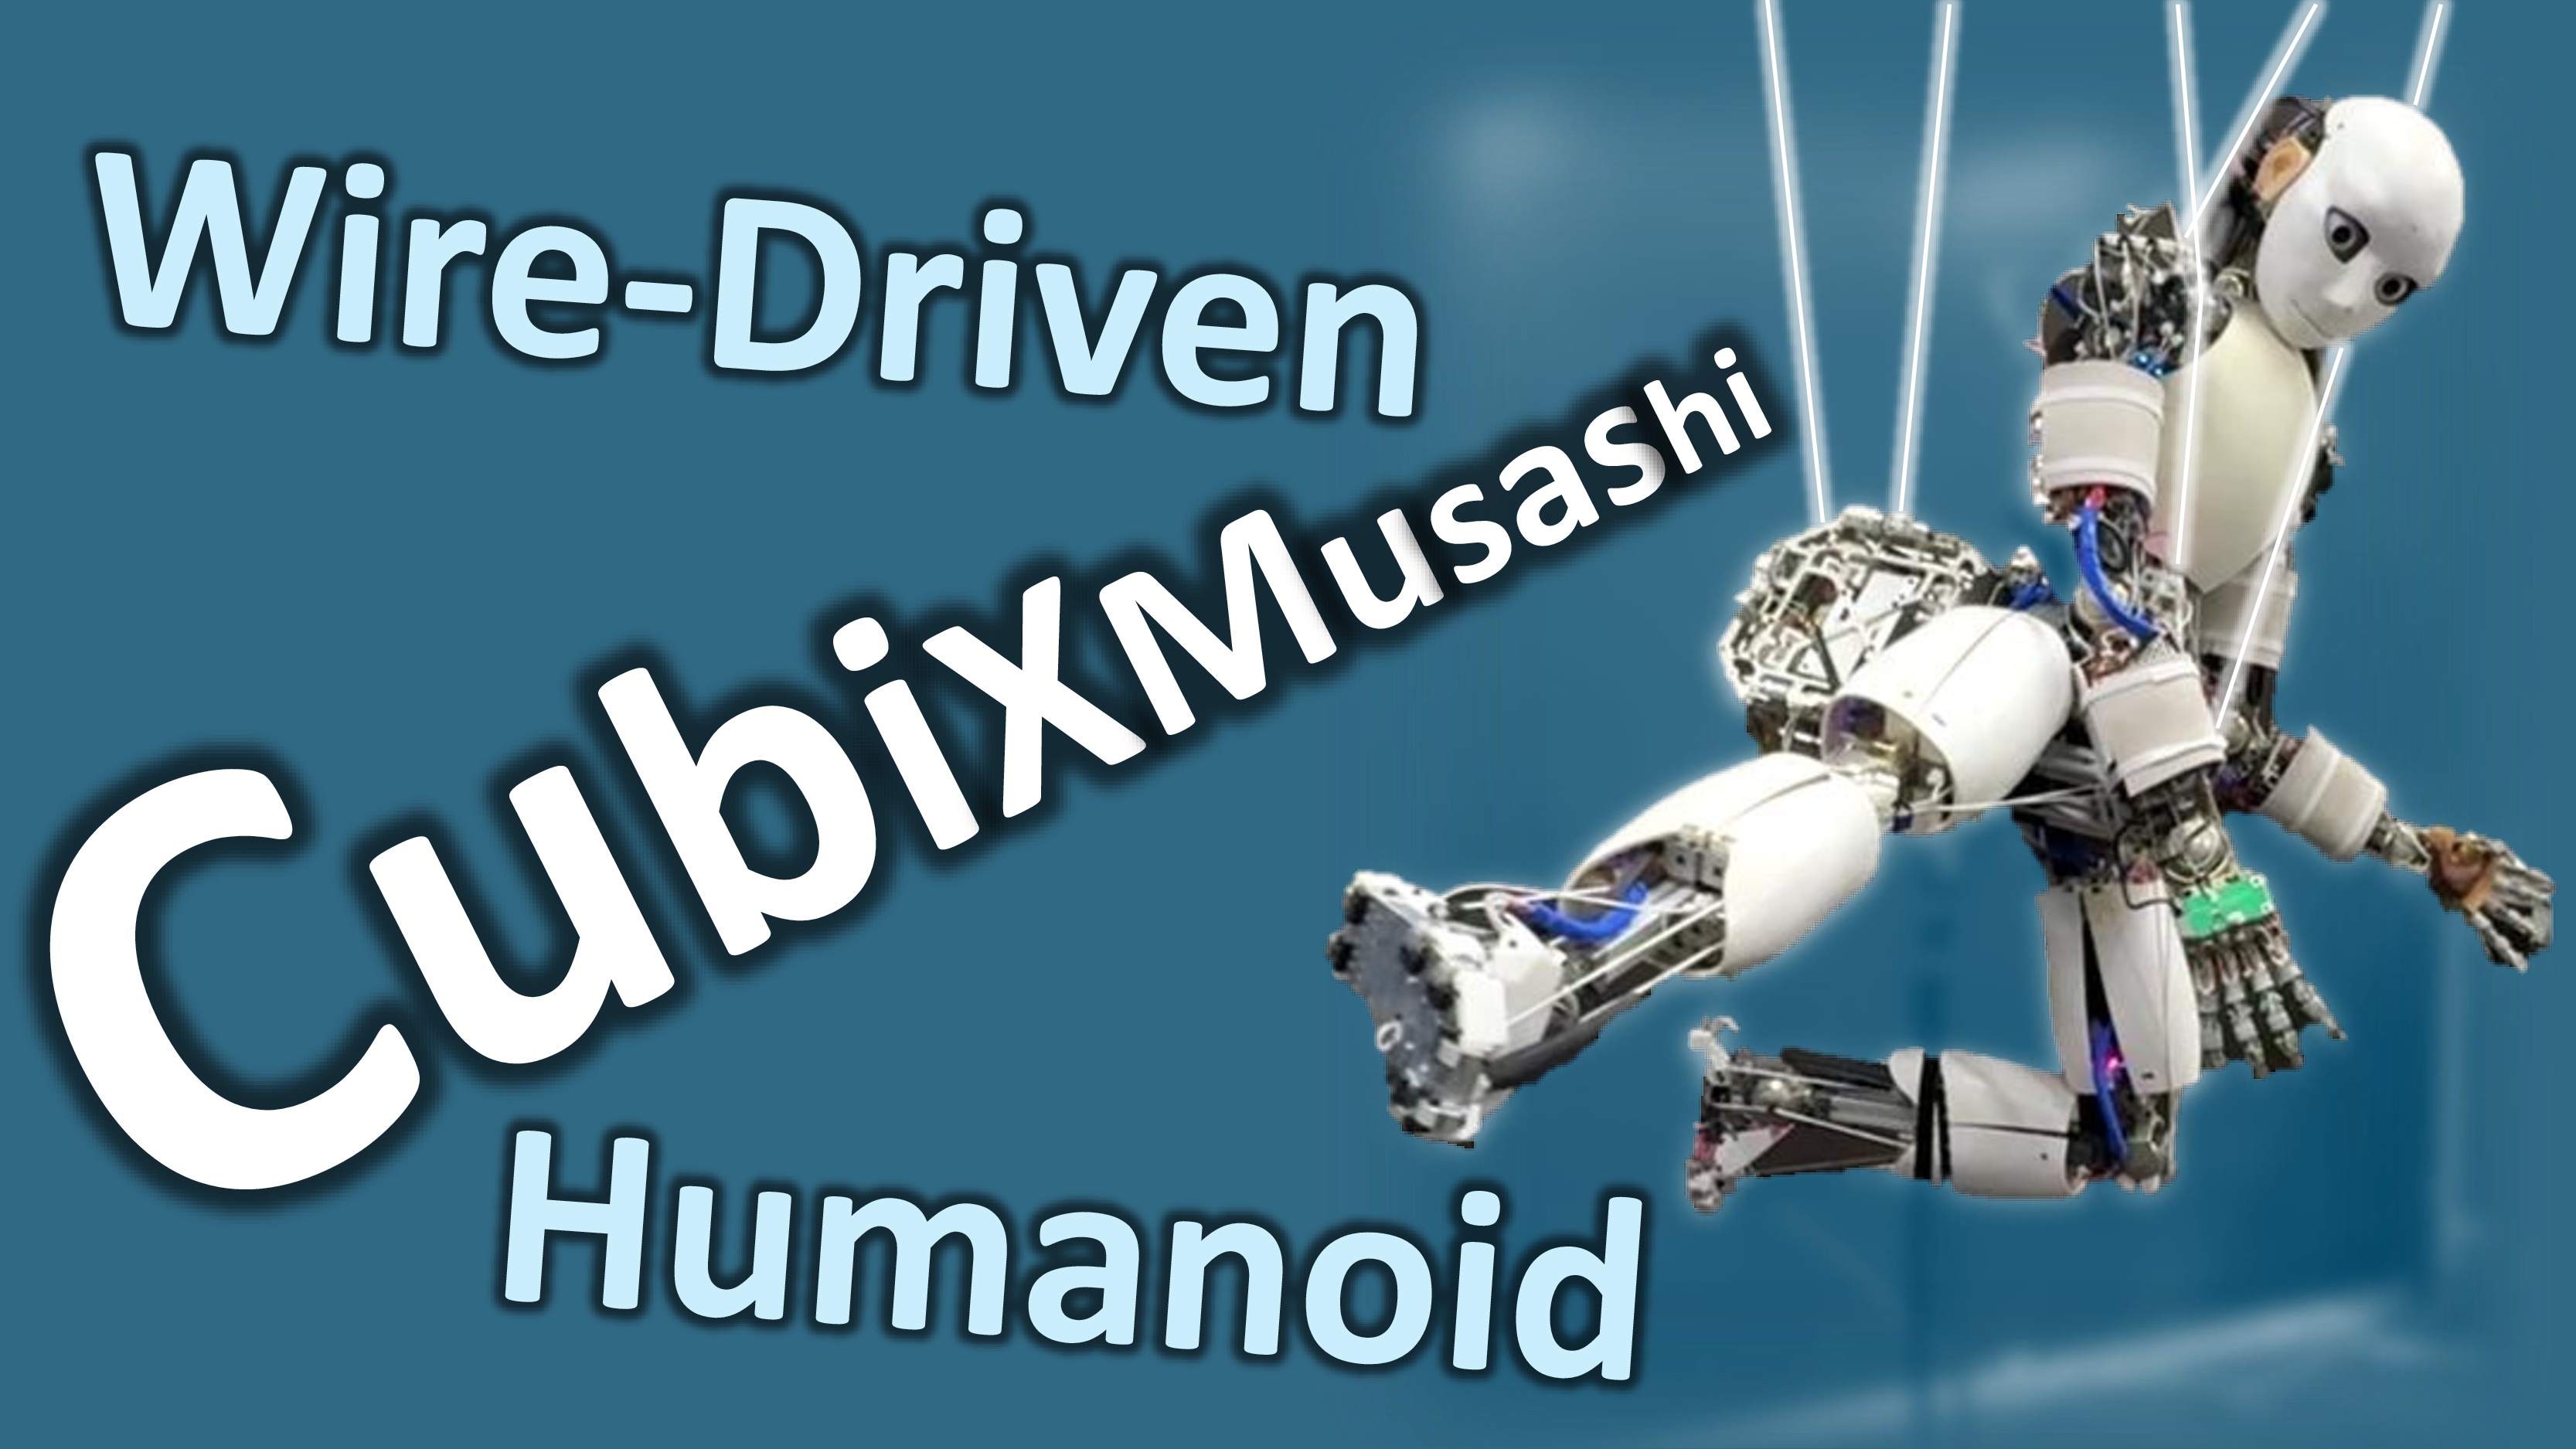
CubiXMusashi: Fusion of Wire-Driven CubiX and Musculoskeletal Humanoid Musashi toward Unlimited Performance

S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, Y. Ribayashi, Y. Sahara, K. Okada
Proceedings of the 2024 IEEE-RAS International Conference on Humanoid Robots (Humanoids2024)

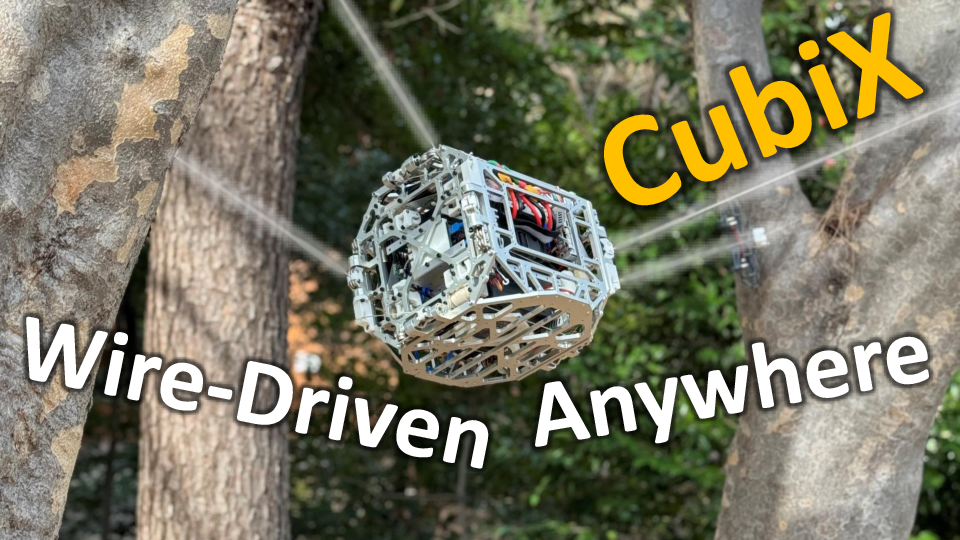
CubiX: Portable Wire-Driven Parallel Robot Connecting to and Utilizing the Environment

S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Okada, M. Inaba
Proceedings of the 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2024)

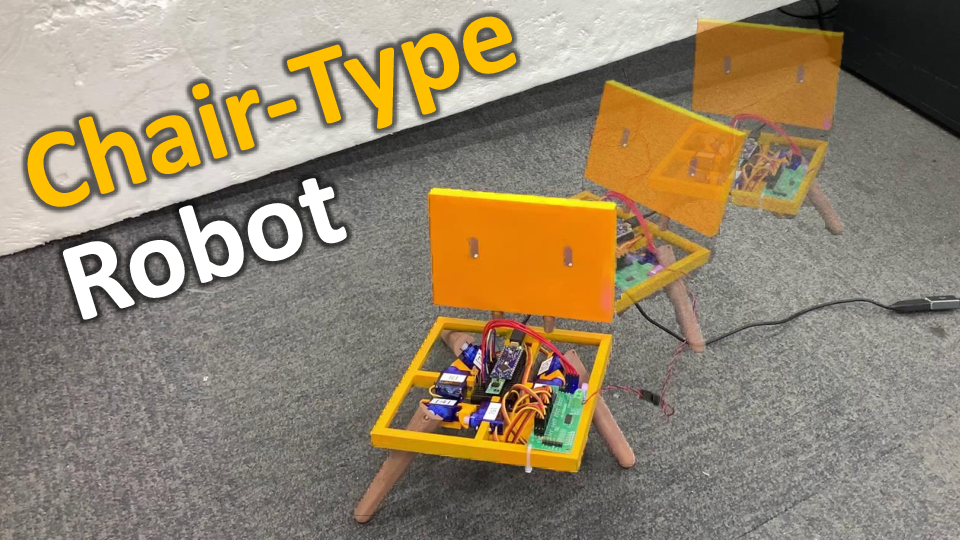
Body Design and Gait Generation of Chair-Type Asymmetrical Tripedal Low-rigidity Robot

S. Inoue, K. Kawaharazuka, K. Okada, M. Inaba
Proceedings of the 2024 IEEE-RAS International Conference on Soft Robotics (RoboSoft2024)